 CodeCogs®
Velocity and Acceleration
Velocity is the measurement of the rate and direction of change in the position of an object. It is a vector physical quantity; both magnitude and direction are required to define it.
Acceleration is the time rate of change of velocity with respect to magnitude or direction; the derivative of velocity with respect to time.
The analysis of velocity and acceleration in a range of mechanisms including Klein's Construction for piston acceleration.
Introduction
The Theory of Machines is concerned with the Motion of parts of machines and the forces which act on those parts. In most cases these forces are not constant and their calculation demands that we know the velocities and accelerations which occur in the various components.
The concept of Instantaneous Centres of Velocity was covered in the section on Mechanisms. In this section the Analysis of Velocity and Acceleration are considered with particular reference to Cranks and Pistons. Klien's Construction for Piston Acceleration is introduced and a description of the Coriolis Component is given.
Analysis of Velocity and Accelerations Components
Velocity
In the diagram the point $P$ moves in the plane $XOY$. The length $OP = r$ and the $\displaystyle\angle POX = \theta$.
Then:
$x = r\cos\theta$ And, $y = r\sin\theta$
Differentiating with respect to time :
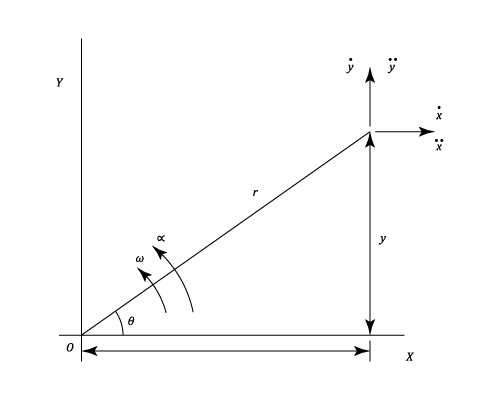
The radial component of Velocity $v$ ( i.e. in the direction of $OP$) is given by:
And using equations (1) and (2)
$\displaystyle v = \dot{r}$ Which is the rate of increase of $OP$
The tangential component of velocity (i.e. Perpendicular to $OP$ in the direction of $\displaystyle \theta$ increasing)
$= \dot{y}\cos\theta - \dot{x}\sin\theta = r\dot{\theta } = r\omega$
Where $\displaystyle \omega = \dot{\theta }$= angular velocity of $OP$
Acceleration
$\ddot{x} = \ddot{r}\cos\theta - \dot{r}\sin\theta \;.\;\dot{\theta } - \dot{r}\sin\theta \;.\;\dot{\theta } - r\cos\theta \;.\;\dot{\theta }^2 - r\sin\theta \;.\;\ddot{\theta }$
$\ddot{y} = \ddot{r}\sin\theta + \dot{r}\cos\theta \;.\;\dot{\theta } + \dot{r}\cos\theta \;.\;\dot{\theta } - r\sin\theta \;.\;\dot{\theta }^2 + r\cos\theta \;.\;\ddot{\theta }$
The Radial components of acceleration
$= \ddot{x}\cos\theta + \ddot{y}\sin\theta = \ddot{r} - r\;\dot{\theta }^2$
And from equation (3)
The Tangential component of acceleration $= \ddot{y}\cos\theta - \ddot{x}\sin\theta$
By substitution:
(Note $\displaystyle \alpha = \ddot{\theta }$ = Angular acceleration of $OP$ )
Of these four terms in equations (4) and (5)
- $\displaystyle \dot{v}$ is the rate of change of radial velocity
- $\displaystyle r\;\omega ^2$ is the centripetal acceleration due to the rotation of $OP$
- $\displaystyle r\;\alpha$ is due to the change in angular velocity.
- $\displaystyle 2\;v\;\omega$is called the compound supplementary acceleration or Coriolis Component. Notice that the direction of this is the same as $\displaystyle r\;\omega$ when $v$ is radially outwards.
The Velocity and Acceleration of a Piston by Analysis
In the following analysis $\displaystyle \omega$ is the uniform angular velocity of the crank. The positive direction of velocity and acceleration is away from the crankshaft.
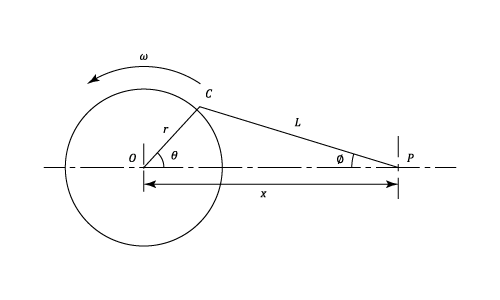
$x = r\cos\theta + l\cos\phi$
And,
$r\sin\theta = l\sin\phi$
$\therefore \;\;\;\;\;\;\cos\phi = \sqrt{1 - \frac{\sin^2\theta }{n^2}}\;\;\;\;\;\;\;\,\;\;\;\;n = \frac{l}{r}$
From the above three equations:
$x = r\,\left (\cos\theta + \sqrt{n^2 - \sin^2\theta } \right )$
Thus Piston velocity,
And Piston acceleration,
Normally $\displaystyle \sin^2\theta$ can be neglected in comparison with $\displaystyle n^2$ and equations (6) and (7) can be reduced as follows:
$\dot{x}\;= - r\,\omega \left (\sin\theta + \frac{\sin2\theta }{2n} \right )$
$\ddot{x}\;= - r\,\omega^2 \left (\cos\theta + \frac{\cos2\theta }{n} \right )$
Instantaneous Centre Method for Velocities.
This has been covered in the section on Mechanisms.
The Vector Method for Velocity and Acceleration
The Law of addition of velocities states that:
Velocity of $B$ = Velocity of $A$ + Velocity of $B$ relative to $A$
i.e. $\underset{OB}{\displaystyle\rightarrow} = \underset{OA}{\rightarrow} + \underset{AB}{\rightarrow}$
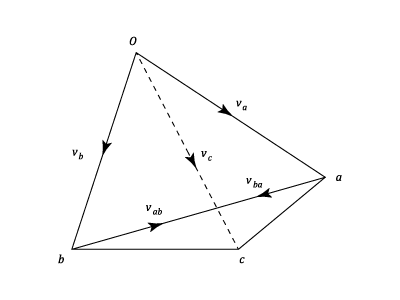
Absolute velocities (or accelerations) are given from $O$ to the corresponding point on the diagram.
For Velocities
- The relative velocity between two points $A$ and $B$ on the same link of a mechanism must be perpendicular to the line joining the points and is equal to $\displaystyle AB\;\omega$ (Equation (2))since $r$ is constant and $\displaystyle \dot{r}$ is zero.
- The relative velocity for two points sliding over one another is along the common tangents of their paths and represents the component $\displaystyle \dot{r}$, $\displaystyle r\;\omega$ is zero since $\displaystyle r = 0$
For Acceleration
The relationships for acceleration are similar to those given for velocity:
- Acceleration of $B$ = Acceleration of $A$ + Acceleration of $B$ relative to $A$
- Equations (4) and (5) are the general expressions for the radial and tangential components of relative acceleration.
- For two points on the same link $\displaystyle v = \dot{v} = 0$ leaving centripetal component $\displaystyle - r\,\omega ^2$ (which can be calculated when the velocities are determined) and the tangential component $\displaystyle r\;\alpha$
- For a uniformly rotating Crank $\displaystyle \alpha = 0$ leaving the centripetal as the only term.
- The Coriolis component arises when a point on one link is sliding along another link which is itself rotating.
If $A$,$B$,$C$, are three points on the same link of a mechanism and $a$,$b$,$c$, are the corresponding points on the velocity (or acceleration) diagram, it can be shown that the triangles $ABC$ and $abc$ are similar. $abc$ is called the Velocity (or acceleration) image of the link.
Klein's Construction for Piston Acceleration
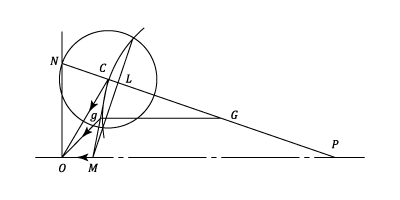
The above is a diagramatic sketch of a piston, connecting rod, and crank assembly where,
- $PC$ is the connecting rod with $C$ the Crank Pin.
- $OC$ is the crank.
- $OP$ is the line of stroke.
- $P$ is the gudgeon pin
The Construction is as follows:
- Extend $PC$ to meet the line through $O$ perpendicular to the line of stroke. Let the point of intersection be $N$.
- Draw a circle centre $C$ and radius $CN$.
- Draw a circle with $CP$ as diameter.
- Let the common cord cut the line $CP$ at $L$ and the line of stroke $PO$ at $M$.
Then the quadrilateral $OCLM$ represents, to a certain scale, the acceleration diagram for $OCP$. It can be shown that this scale is $\displaystyle \omega ^2$.
- The Centripetal acceleration of the crank pin is $\displaystyle C\;O\;\times \omega ^2$
- The piston acceleration is $\displaystyle M\;O\;\times \omega ^2$
- $CL$ is the Centripetal component and $LM$ the Tangential component of the acceleration of $P$ relative to $C$, so that $CM$ is the acceleration image of $CP$.
- For any point $Q$ on $CP$ draw a line parallel to $OP$ cutting $CM$ in $q$. The acceleration of $Q$ is $q\;O\times\omega ^2$ in magnitude and direction.
Example 1 [imperial]
An aeroplane $A$ flying at 180 m.p.h. in a direction $\displaystyle 30^{0}$ North of West sights another $B$ due North of $A$. After 30 seconds flying $B$ is seen to be in a North-Easterly direction from $A$ and after a further 45 seconds $B$ is directly astern of $A$. If $B$ is flying at a constant speed in a direction due South, find:
- a) The speed of $B$
- b) For how long $B$ is within 2 miles of $A$
In the following diagram the Paths of $A$ and $B$ are shown. Their three particular positions are $\displaystyle a_1\,,\,a_2\,,\,a_3$ and $b_1\,,\,b_2\,,\,b_3$ respectively.
$a_1\;a_2 = 1.5\;miles$ (30 seconds flying)
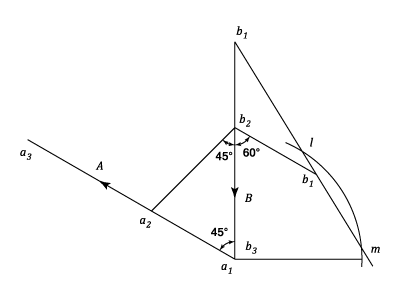
By scaling or by calculation $\displaystyle b_2\;b_3 = 2.05\;miles$ and occupies 45 seconds of flying time.
Hence, Speed of $B$ = $\displaystyle\frac{2.05}{45}\times 3600 = 164\;m.p.h.$
Relative displacement of $B$ to $A$ = displacement of $B$ - displacement of $A$
i.e. $b_1\;{b_{1}}^{'} = b_1\;b_2 + b_2\;{b_{1}}^{'}$
In the first 30 seconds $\displaystyle b_2\;{b_{1}}^{'}\;= - a_1\;a_2$
Assuming that A is at rest at $\displaystyle a_1$ , the relative path of $B$ is $\displaystyle b_1\;{b_{1}}^{'}$ produced and a circle centre $\displaystyle a_1$ and of radius 2 miles cuts this path at 1 and $m$. Between 1 and $m$, $B$ lies within 2 miles of $A$.
$1\;m = 1.85\;miles$
But $b_1\;{b_{1}}^{'} = 2.47\;miles$
This represents 30 seconds of relative displacement
But, Time corresponding to 1 mile = $\displaystyle\frac{1.85}{2.47}\times 30 = 22.5\;seconds$
- a) The speed of $B$ is $164\;m.p.h.$
- b) $22.5\;seconds.$
Example 2 [imperial]
The quick return mechanism for a shaping machine is shown in the diagram. The upper end of the slotted lever is pin jointed to the ram and tool box at D so that this point moves in a horizontal straight line whilst the lower end slides over a block at $C$ mounted on trunnion bearings.
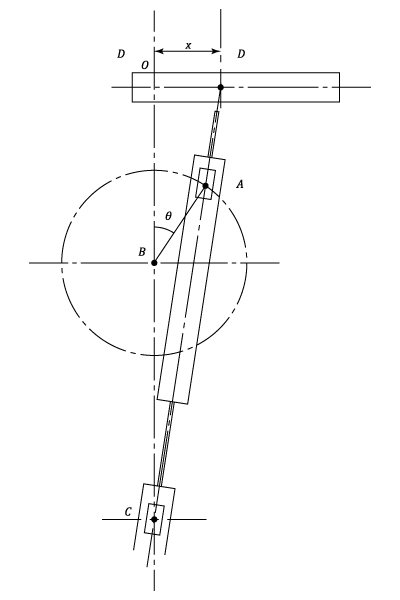
It is driven by the crank $BA$ which turns at uniform angular velocity $\displaystyle \omega$ about the fixed centre $B$, through the slide block at $A$. If the ratio of the lengths $\displaystyle\frac{BA}{BC}$ is denoted by $k$ and $\displaystyle \theta$ is the angle $BA$ has turned from the upwards vertical, show from the geometry that the displacement of the tool box from its mid point is :
$x = C\,D_o\;\left (\frac{k\sin\theta }{1 + k\cos\theta } \right )$
And determine the corresponding velocity and acceleration.
$C\;D_o = 24\;in.\;,\;C\,B = 15\;in.\;,B\,A = 5\;in.$ and the crank speed is $40\;r.p.m..$, find these values for $\theta = 30^{0}$
From the diagram it can be seen that:
But,
Combining equations (8) and (9)
$\therefore\;\;\;\;\;\;\;x = CD_o\times \frac{k\;\sin\theta }{1 + k\;\cos\theta }$
Differentiating to find the velocity:
$\dot{x} = CD_o\times \frac{(1 + k\;\cos\theta )\;k\;\cos\theta - k\;\sin\theta (- k\;\sin\theta }{(1 + k\;\cos\theta)^2 }\times\omega$
$= CD_o\times \frac{k\,\omega (\cos\theta + k)}{(1 + k\;\cos\theta)^2 }$ $\left \omega = \displaystyle\frac{d\theta }{dt}$ which is constant
The second differentiation gives the acceleration:-
$\ddot{x} = CD_o\times k\,\omega ^2\times \frac{(1 + k\;\cos\theta )^2(- \sin\theta ) - (\cos\theta + k)^2(1 + k\,\cos\theta )(- k\,\sin\theta )}{(1 + k\,\cos\theta )^4}$
$= CD_o\times k\,\omega ^2\times \frac{2k^2 - 1 + k\,\cos\theta }{(1 + k\,\cos\theta )^3}$
At the given values:
$k = 0.333\;\;\;\;\omega = 40\times \frac{2\pi }{60} = \frac{4\pi }{3}\;\;\;rads.sec.^{-1}$
$x = 24\times \frac{0.333\times 0.5}{1 + 0.333\times 0.866} = 3.1\;in.$
$\dot{x} = 24\times 0.333\;\left (\frac{4\pi }{3} \right )\times \frac{0.866 + 0.333}{(1 + 0.333\times 0.866)^2} = 24.2\;in.\;sec.^{-1}$
$\ddot{x} = 24\times 0.333\;\left (\frac{4\pi }{3} \right )^2\times 0.5\times \frac{2\times 0.333^2 - 1 + 0.333\times 0.866}{(1 + 0.333\times 0.866)^3}$
$\therefore\;\;\;\;\;\;\;\ddot{x} = 16.1\;ft.\;sec.^{-2}$
Example 3 [imperial]
In the mechanism shown in the diagram, the crank $AC$ is 5 in. long and rotates clockwise about a centre $A$ with a speed of 100 r.p.m.. The slotted lever $BC$ rotates about a fixed centre $B$, 10 in. vertically below $A$. Its centre of gravity $G$ is 9 in. from $B$, its weight 25 lb. and its radius of gyration about $G$ is 8 in.
For the position shown in which the angle $BAC$ is $135^{0}$ determine graphically,
- The angular velocity of $BC$.
- The linear velocity of $G$.
- The velocity of the sliding block in slot.
- The angular velocity of the pin at $C$ relative to the block.
Also calculate the kinetic energy stored in the lever $BC$.
Let the point at the end of the crank be $\displaystyle C_1$ and the "coincident" point on $BC$ be $\displaystyle C_2$. Note that these two points are slidding over each other in the direction of the common tangent $BC$.
- Velocity of $C_1$
$V_C_1 = 5\times 100\times \frac{2\pi }{60} = 52.3\;in.sec.^{-1}$
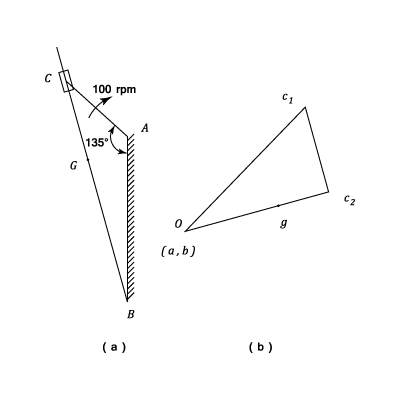
The Construction of the vector diagram (b)
Draw $\displaystyle oc_1$ perpendicular to $AC$ to represent $\displaystyle V_c_1$
From $\displaystyle C_1$ draw a line parallel to $CB$ to represent the velocity of sliding of $\displaystyle C_2$ relative to $\displaystyle C_1$ .
From $O$ draw a line perpendicular to $BC$ to represent the velocity of $\displaystyle C_2$ which is turning about the fixed centre at $B$.
The intersection of these last two lines gives the point $\displaystyle c_2$
- The angular velocity of $BC$
$\omega _{BC} = \frac{oc_2}{BC} = \frac{45.1}{13.98} = 3.23\;rad.\,sec.^{-1}$
- Velocity of $G$
$v_g = BG\times \omega _{BC} = 9\times 3.23 = 29.1\;in,\;sec.^{-1}$
Velocity of sliding = $c_1\;c_2 = 26.6\;ft.\,sec.^{-1}$
- Angular Velocity of pin relative to the block
$= \omega _{AC} - \omega _{BC} = 10.7 - 3.23 = 7.24\;rad.\,sec.^{-1}$
- Kinetic Energy stored
Total K.of BC = Linear + Angular Energy
$\therefore\;\;\;\;\;\;\;\frac{1}{2}\times \frac{25}{32.2\times 12}\times 29.1^2 + \frac{1}{2}\times \frac{25\times 8^2}{32.2\times 12}\times 3.23^2 = 49\;in.\;lb.$
(Note For any of you not used to the Imperial system of measurements, the 32.2 is the acceleration due to gravity in ft./sec sq. and the 12 converts this to in/sec.sq.)
- The angular velocity of $BC$ is $3.23\;rad.\,sec.^{-1}$
- The linear velocity of $G$ is $29.1\;in.\;sec.^{-1}$
- The Velocity of $C_1$ is $52.3\;in.sec.^{-1}$
- The angular velocity of the pin at $C$ is $7.24\;rad.\,sec.^{-1}$
- The Kinetic Energy is $49\;in.\;lb.$
Example 4 [imperial]
In the linkwork shown in the following Diagram, the crank $AB$ rotates about $A$ at a uniform speed of 120 r.p.m. The lever $DC$ oscillates about the fixed point $D$ being connected to $AB$ by the coupler $BC$. The block $F$ moves in horizontal guides and is driven by the link $EF$.
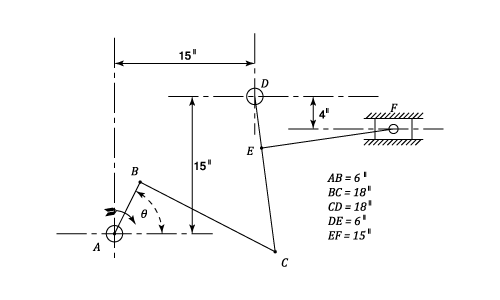
When the angle $\displaystyle \theta = 45^{0}$ determine:
- a) The velocity of $F$
- b) The angular velocity of $DC$
- c) The rubbing speed at the pin $C$ which is 2 in. diameter.
$AB$ = 6 in. $BC$ = 18 in. $CD$ = 18 in. $DE$ = 6 in. and $EF$ = 15 in.
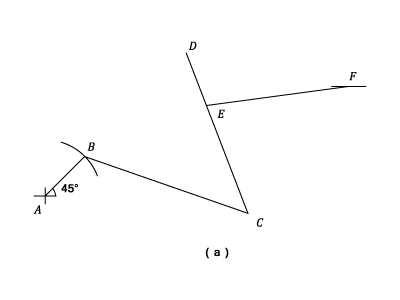
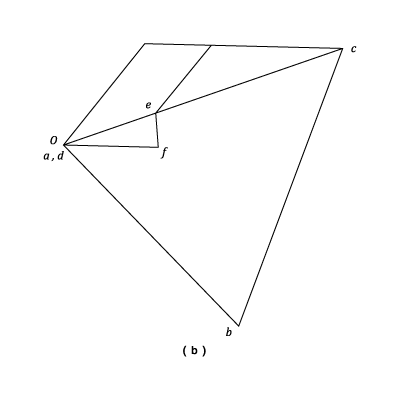
The configuration of the links when $\displaystyle \theta = 45^{0}$ is shown in diagram (a). The velocity diagram (b) is drawn as follows:
- $\displaystyle ob = v_b = 6\times 120\times \frac{2\pi }{60} = 75.4\;in.\;sec^{-1}$ and is drawn perpendicular to $AB$
- $v_C$ = $v_B$ + velocity of $C$ relative to $BC$ = $ob + bc$ where $bc$ is perpendicular to $BC$
- $B$ must move perpendicular to $DC$ and hence its absolute velocity is $oc$ which is found by intersection with $bc$.
- $D$ is a fixed point and coincides with $o$. Hence $co$ is the velocity image of $CD$. $e$ divides $co$ in the same proportion as $E$ divides $CD$.
i.e. $\displaystyle \frac{oe}{ce} = \frac{DE}{CE} = \frac{1}{2}$
- The velocity of $E$, $ef$ is perpendicular to $EF$, but $F$ must move horizontally, hence the point $f$ is determined.
Velocity diagram
Answers
- Velocity of $F$ is $of = 28.6\;in.\;sec^{-1}$
- Angular velocity of $DC$ = $\displaystyle\frac{v_C}{DC} = \displaystyle\frac{oc}{DC} = \displaystyle\frac{89}{18} = 4.94\;rds.\;sec.^{-1}$ anti-clockwise.
- Angular velocity of $BC$ is Velocity of $C$ relative to $B$/ $BC$
Angular velocity of $BC$ is $\displaystyle\frac{bc}{BC} = \displaystyle\frac{89}{18} = 4.94\;rad.\,sec.^{-1}$
This is anti-clockwise movement since $C$, relative to $B$, is moving "upwards".
- The rubbing velocity at $C$ = Radius of pin $X$ difference of angular velocity = 0
- a) The velocity of $F$ is $28.6\;in.\;sec^{-1}$
- b) The angular velocity of $DC$ is $4.94\;rds.\;sec.^{-1}$
- c) The rubbing speed at the pin $C$ is $0$.
Example 5 [imperial]
In the mechanism shown in the diagram, the crank $O_1A$ rotates at a constant speed of 60 r.p.m., in a clockwise direction, imparting a vertical reciprocating motion to the rack $R$, by means of the toothed quadrant $Q$. $O_1$ and $O_2$ are fixed centres and the slotted bar $BC$ and the quadrant $Q$ rock on $O_2$.
Determine:
- a) The linear speed of the rack when the angle $O_2\;O_1\;A$ is $135^{0}$.
- b)The ratio of the times of lowering and raising the rack.
- c) The length of the stroke of the rack.
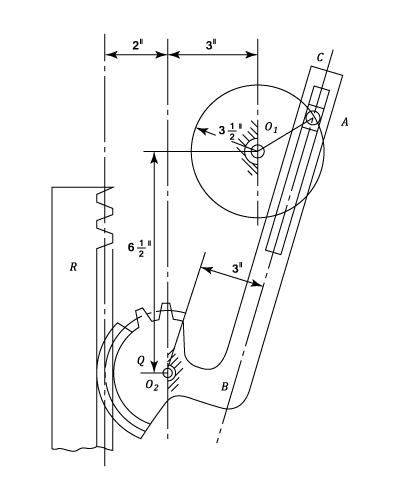
The position of the mechanism when $\angle O_2\,O_1\;A = 135^{0}$ is shown in diagram (a) and the Velocity diagram (b)
fig 2.11 a and b
- $\displaystyle 0\,a_1$ Velocity of block $A = 3.5\times 2\pi = 22\;in.\,sec.^{-1}$ perpendicular to $O_1\;A$
- $\displaystyle a_1\,a_2$ = The velocity of sliding of $A$ in $BC$ parallel to $AB$.
- $\displaystyle o\;a_2$ = The velocity of the point on $BC$ coincident with block $A$ and perpendicular to $\displaystyle O_2\;A$
The Angular velocity of the quadrant $\displaystyle = \frac{o\,a_2}{O_2\,A} = \frac{14.7}{9.96} = 1.48\;rad.\;sec.^{-1}$
Answers
- a) The Linear speed of the rack = The radius of the quadrant $X$ the Angular Velocity.
$= \frac{14.7}{9.96} = 2.96\;in.\;sec.^{-1}$
- b) If a circle, centre $\displaystyle O_2$, and radius 3 in. is drawn, the limits of the stroke of $BC$ ( and hence the rack) are when the tangent at $A$ is also a tangent to this circle i.e. $A$' and $A$''
$\angle A'\;O_1\,A'' = 112.5^{0}$
Therefore, The Ratio of times = $\displaystyle\frac{360 - 112.5}{112.5} = 2.21$
- c) The length of stroke = The radius of the quadrant $X$ Angular rotation.
$= 2\left (\frac{180 - 112.5}{57.3} \right ) = 2.21\;in.$
- a) The linear speed of the rack is $2.96\;in.\;sec.^{-1}$
- b)The ratio of the times is $2.21$
- c) The length is $2.21\;in.$
Example 6 [imperial]
The diagram shows a mechanism in which the crank $AB$ turns uniformly at 180 r.p.m., the blocks at $D$ and $E$ working in frictionless guides. $AB = 1.5 ft.$; $BD = 5 ft.$ ; $BC = 3 ft.$ ; $CE = 3 ft.$
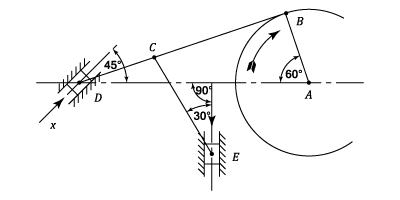
Draw the velocity vector diagram and state the velocities of the blocks $D$ and $E$ in their guides.
Find the turning moment at $A$ if a force of 100 lb. acts on $D$ in the direction of the arrow $X$ and a force of 150 lb. acts on $E$ in the direction of arrow $Y$.
The mechanism is drawn to scale in the following diagram
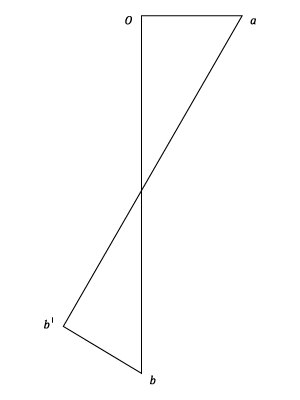
The Velocity diagram, drawn to scale
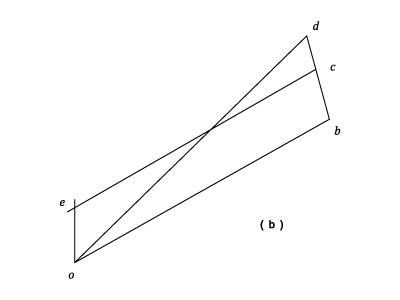
$v_B = ob = 1.5\times 180\times \frac{2\pi }{60} = 28.2\;ft.\,sec^{-1}$
- The relative velocity $bd$ is perpendicular to $BD$ and $od$ is parallel to the movement of $D$
- $\displaystyle \frac{b\,c}{c\,d} = \frac{B\,C}{C\,D}$ and the relative velocity ce is perpendicular to $CE$.
- $oe$ is in the direction of motion of $E$.
- Velocity of $D$ is $od = 31.4 ft./sec.$ to the right.
- Velocity of $E$ is $oe = 5.5 ft./sec.$ upwards.
Power input = Force $X$ velocity.
The Force at $E$ is opposing motion
Therefore, Power is $100 \times v_P - 150\times v_E = 100\times 31.4 - 150\times 5.5$
Thus the Power Input $\displaystyle 2310\;ft.\;lb.\;sec^{-1}$ = The power output ( Neglecting losses)
$= \tau \times 180\times \frac{2\pi }{60}$
$\therefore \;\;\;\;\;\;\;\;\tau = \frac{2310}{6\pi } = 122.5\;lb.\,ft.$
- $\tau =122.5\;lb.\,ft.$
Example 7 [imperial]
For the engine shown in the Diagram, the crank radius $CB$ is 2.25 in. and the length of the connecting rod $AB$ is 9.25 in. between centres.
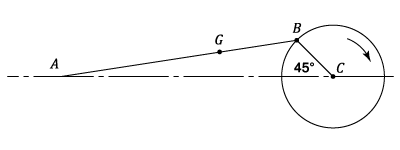
The centre of gravity of the rod is at $G$ which is 3 in. from $B$. The engine speed is 1200 r.p.m.
For the position shown, in which $CB$ is turned $\displaystyle 45^{0}$ from $CA$, find graphically the velocity of $G$ and the angular acceleration of $AB$. Indicate the direction of each of these values.
The velocity of $B$, $\displaystyle v_b = 2.25\times 1200\times \frac{2\pi }{60} = 283\;in.\,sec.^{-1}$. Note that $v_B$ is perpendicular to $CB$
- Draw $cb$ to represent $v_B$ to scale
- The velocity of $A$ relative to $B$ must be perpendicular to $BA$ and is represented by $ba$.
- A must move in the direction $CA$ and hence its absolute velocity is represented by $ca$.
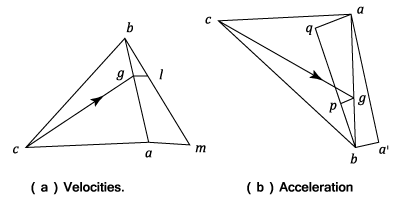
- $ba$ is the velocity image of $BA$ and $g$ divides it in the ratio $\displaystyle\frac{BG}{BA}$. The line $blm$ is used for this construction.
- The Angular velocity of $AB$ is given by:
$\omega _{AB} = \frac{b\,a}{B\,A} = \frac{204}{9.5} = 21.5\,rad.\,sec^{-2}$ The acceleration is anti-clockwise since the velocity of $A$ relative to $B$ is parallel to $ba$.
- The Acceleration of$\displaystyle B = 2.25\times \left (1200\times \frac{2\pi }{60} \right )^2 = 35,500\;in.\,sec^{-2}$ in the direction of $BC$
- $cb$ is drawn on the acceleration diagram (b) to represent the acceleration of $B$
- The acceleration of $A$ relative to $B$ has the following components. Centripetal $\displaystyle = AB\,\omega _{AB}^{2} = 9.5\times 21.5^2 = 4400\,in.\,sec^{-2}$ represented by $ba$' in the direction of $AB$.
Tangentiallyrepresented by $a$'$a$ perpendicular to $AB$. The Absolute acceleration $A$ is ca parallel to $CA$. $ab$ is the image of $AB$ and $g$ divides it in the ratio $\displaystyle\frac{BG}{BA}$ as before.
- The acceleration of $\displaystyle G = cg = 29,800\;in.\,sec^{-2}$
- The acceleration of $\displaystyle AB = \frac{a'a}{AB} = \frac{24800}{9.5} = 2610\;rad.\,sec^{-2}$ clockwise since the tangential acceleration of $A$ relative to $B$ is parallel to $a$'$a$.
- The velocity of $G$ is $29,800\;in.\,sec^{-2}$
- The angular acceleration of $AB$ is $2610\;rad.\,sec^{-2}$
Example 8 [imperial]
In a four bar chain $ABCD$, $A$ and $D$ are fixed centres 2.5 in. apart on a horizontal line. The driving crank $AB = 1 in.$, the driven crank $DC = 1.5 in.$ and the coupler $BC = 1.5 in.$ with its centre of gravity $G$ at 0.5 in. from $C$. When $AB$ is turned through $\displaystyle 60^{0}$ anti-clockwise from $AD$, $B$ and $C$ are on the same side as $AD$.
If, for this position, the angular velocity of $AB$ is 20 rad. / sec. anti- clockwise, find the angular velocity of $BC$ and $DC$ and the linear velocity of $G$.
If also for this position the angular acceleration of $AB$ is $\displaystyle 100\;rad.\;sec.^{-2}$ anti-clockwise, find the angular acceleration of $BC$ and $DC$ and the linear acceleration of $G$.
On the velocity Diagram (a) let $I$ be the instantaneous centre of $BC$.
$\omega _{BC} = \frac{v_b}{IB} = 20\times \frac{1}{2.10} = 9.53\;rad.\;sec^{-1}$
$v_c = \omega _{BC} \times IC = 9.53\times 1.28 = 12.2\;in.\;sec.^{-1}$
$v_G = \omega _{BC} \times IG = 9.53\times 1.44 = 13.7\;in.\;sec.^{-1}$
$\omega _{CD} = \frac{v_C}{CD} = \frac{12.2}{1.5} = 8.13\;rad.\;sec^{-1}$
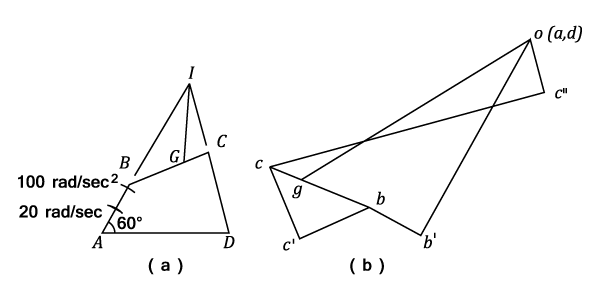
On the acceleration Diagram (b)
Acceleration of $B$ = $ob$'(Centripetal) + $b'b$ (Tangential) $= 1\times 20^2 + 1\times 100$
Acceleration of $C$ relative to $B$ = $bc$'(Centripetal) + $c'c$(Tangential)
$= BC\times {\omega_{BC}}^{2} +$ an unknown $= 136 +$ an unknown
Acceleration of $C$ relative to $D = oc$''(Centripetal) + $c$''$c$(Tangential)
$= CD\times {\omega_{CD}}^{2} +$ an unknown $= 99.2 +$ an unknown
The point $c$ is found from the intersection of the two lines of unknown magnitude.
The Angular acceleration of $BC$ is given by:
$\alpha _{BC} = \frac{cc'}{BC} = \frac{138}{1.5} = 92.0\;rad.sec.^{-2}$
Similarly the Angular acceleration of $CD$
$\alpha _{CD} = \frac{cc''}{BC} = \frac{504}{1.5} = 336.0\;rad.sec.^{-2}$
The linear acceleration of $G = og$ where $\displaystyle \frac{bg}{cg} = \frac{BG}{CG} = 477\;in.sec.^{-2}$
- The angular velocity of $BC$ is $9.53\;rad.\;sec^{-1}$ and for $DC$ is $8.13\;rad.\;sec^{-1}$
- The \b{linear velocity of $G$ is $13.7\;in.\;sec.^{-1}$
- The angular acceleration of $BC$ is $92.0\;rad.sec.^{-2}$ and for $DC$ is $336.0\;rad.sec.^{-2}$
- The linear acceleration of $G$ is $477\;in.sec.^{-2}$